Likes 0Comments 0
Humanoid & robot AI research · ETH Zurich · ACP research team · 2026-10-22
ETH researchers plan body contacts to help humanoids cross obstacles
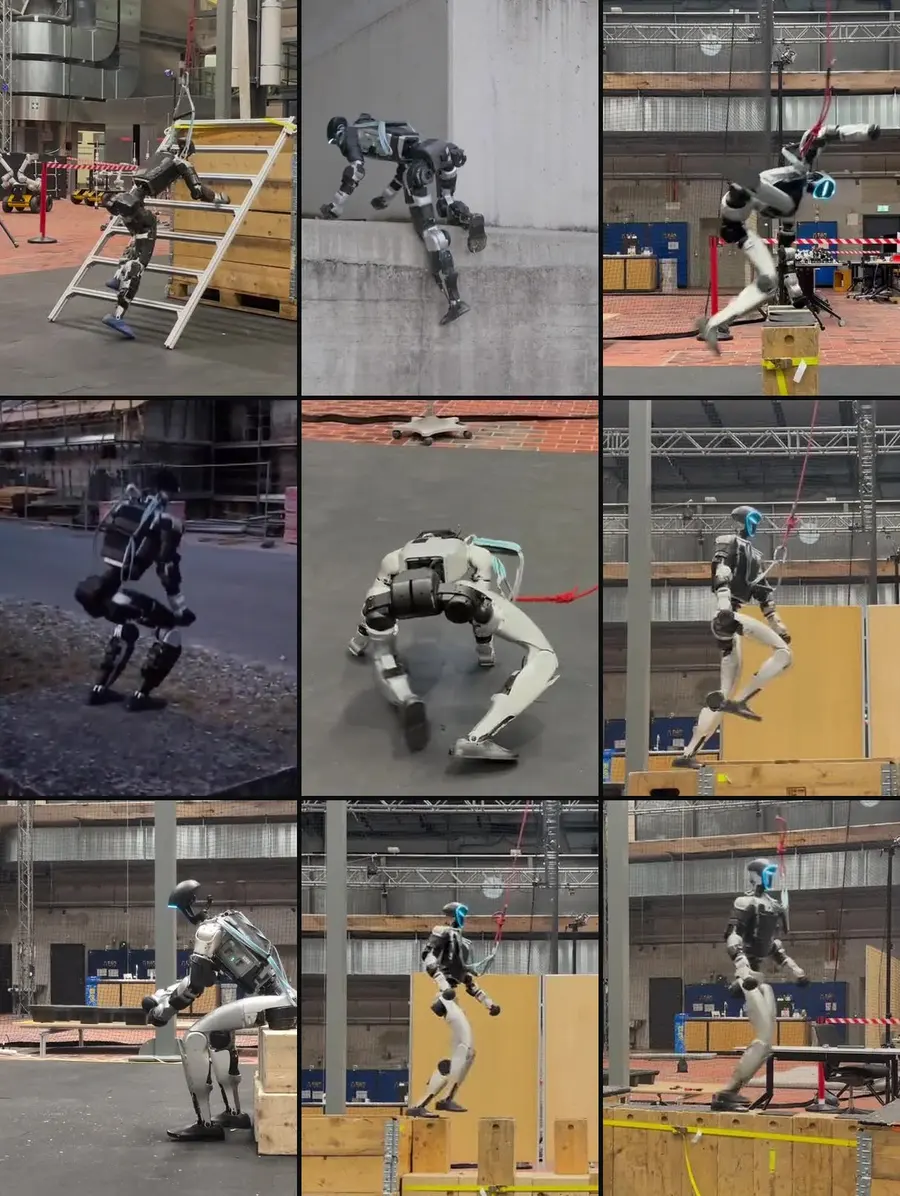 Photo: ACP research team · ETH Zurich · real-robot demonstration stills
Three key points
- ACP plans body–terrain contacts and a controller turns them into whole-body motion.
- The official project shows real Unitree G1 ladder climbing, vaulting and recovery demonstrations.
- The October 22 preprint is under review; these demonstrations are not general autonomy or field-safety certification.
Story summary
ETH researchers present ACP, which plans where a humanoid's body should contact terrain. A LiDAR-equipped Unitree G1 demonstrates ladder climbing, vaulting and getting up with one control policy. The preprint is under review; demonstrations do not establish autonomous work or safety across arbitrary environments.
Login required. Log in to recommend stories and write comments.
Comments 0
Be the first to comment.